Lessons, labs, and weekly project work

Materials are grouped by month and week. Each week pairs a lesson with a hands-on lab, an assignment, and a step toward that month's project.

View Lesson and Download PDF open the lesson file; Start Lab opens the lab brief. Enrolled students also receive the institution's learning-platform links when those are published.

Duration
6 months
Weekly modules
24 weeks
Each week
Lesson, lab, project
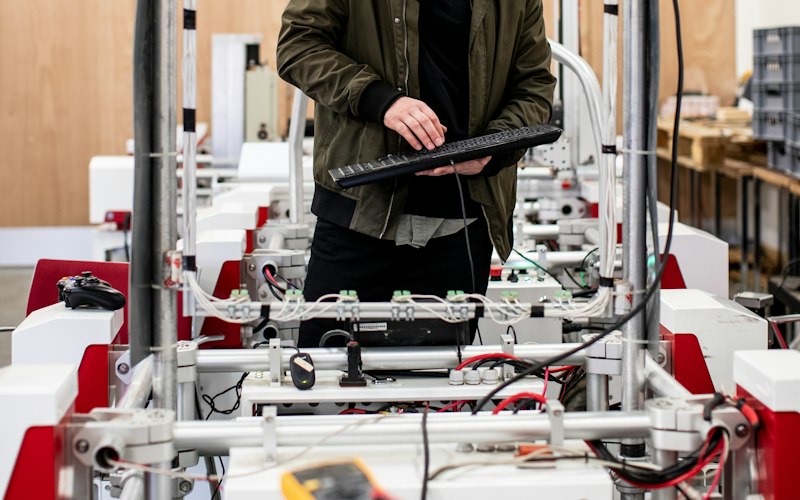
Student programming a robotics lab rig during a hands-on integration session

Month 01 06

Robotics Fundamentals

Robot types, sensors, motors, frames, and Python — then a basic mobile robot in simulation.

Week 01

Introduction to Robotics

Objectives
Robot definitions, applications, sense–plan–act, Python setup
Lecture notes
Architecture and program orientation
Reading
Introductory robot types and applications
Video
What is a robot? (placeholder)
Lab
Install tools and open a mobile-robot world
Assignment
One-page robot system diagram
Quiz
Terminology and categories
Project
Start the Month 1 simulation sketch
Week 02

Sensors and Actuators

Objectives
Sensor classes, encoders, IMUs, ranging, cameras, actuators
Lecture notes
Sampling, noise, and motor types
Reading
Encoder and ranging primer
Video
Sensing the environment (placeholder)
Lab
Plot simulated encoder and range data
Assignment
Sensor-selection worksheet
Quiz
Match sensors to tasks
Project
Add bumper and range sensors
Week 03

Motors and Electronics

Objectives
DC/stepper/servo use, PWM concept, electrical safety, wheel motion
Lecture notes
Drivers, power, and frames
Reading
Motor-control primer
Video
From voltage to motion (placeholder)
Lab
Command differential-drive speeds
Assignment
Turn-rate worksheet
Quiz
Motors, PWM, coordinates
Project
Open-loop drive commands
Week 04

Python for Robotics

Objectives
Functions, collections, simple classes, documentation
Lecture notes
Python patterns used later in ROS 2
Reading
Python essentials for engineers
Video
Python patterns for robots (placeholder)
Lab
Threshold range data and flag obstacles
Assignment
Commented helper module
Quiz
Types, control flow, functions
Project
Mobile robot stops near an obstacle

Month 02 06

Robot Programming and Control

Python, C++ fundamentals, ROS 2 communication, and PID motion control.

Week 01

Python and C++ Fundamentals

Objectives
Packages, C++ literacy, compiled vs interpreted workflows
Lab
Tiny C++ program plus a Python helper
Assignment
Velocity-limiter port to C++ pseudocode
Project
List nodes for the autonomous robot
Week 02

ROS 2 Nodes and Topics

Objectives
Graph, publisher/subscriber, inspection tools
Lab
Publish velocity-like commands
Assignment
Node/topic graph
Project
Connect a timer or keyboard node
Week 03

Services, Actions, Communication

Objectives
When to stream, request, or track a long task
Lab
Start/stop wander service
Assignment
Communication-pattern design note
Project
Stop-on-command service
Week 04

PID and Motion Control

Objectives
P, I, D terms; tune heading or distance; judge response
Lab
Reach a goal pose without spinning
Assignment
Gains and response reflection
Project
Simulated autonomous robot holds heading and stops

Month 03 06

Robot Modeling and Simulation

Kinematics, URDF, Gazebo, RViz, and manipulator trajectories.

Week 01

Robot Kinematics

Objectives
Frames, FK vs IK, joints, planar example
Lab
Animate a 2-link planar arm
Project
Choose a 3-DOF arm layout
Week 02

URDF and Robot Modeling

Objectives
Read and write URDF, check common errors, visualize
Lab
3-joint arm model in a viewer
Project
Visual and collision meshes
Week 03

Gazebo Simulation and RViz

Objectives
Physics world vs visualization, spawn, inspect frames
Lab
Command a joint trajectory in a world
Project
Pick-ready tabletop scene
Week 04

Trajectory Planning

Objectives
Joint vs task space, interpolation, singularity awareness
Lab
Three-waypoint arm motion
Project
Arm reaches a target series

Month 04 06

Computer Vision and AI

OpenCV, depth sensors, detection, tracking, and vision-guided motion.

Week 01

Computer Vision Fundamentals

Objectives
Image formation, color spaces, cameras vs depth
Lab
Load, convert, and crop images
Project
Choose detection targets
Week 02

OpenCV and Image Processing

Objectives
Blur, threshold, morphology, contours, centroids
Lab
Isolate a colored object
Project
Color-based detection pipeline
Week 03

Object Detection and Tracking

Objectives
Detect vs track, bounding boxes, occlusion and lighting
Lab
Track a moving object and log the path
Project
Keep a lock on a target
Week 04

ML and Vision-Guided Robotics

Objectives
Labeled examples, train/test idea, pixels to motion, safety
Lab
Approach a detection and stop
Project
Vision-based object detection robot

Month 05 06

Autonomous Robotics

Localization, mapping, SLAM, planning, and sensor fusion.

Week 01

Localization and Mapping

Objectives
Odometry drift, occupancy grids, global vs relative pose
Lab
Build a grid from range scans
Project
Record a practice map
Week 02

SLAM

Objectives
Simultaneous mapping and localization, loop closure idea
Lab
Produce a usable 2D map
Project
Map for the navigation stack
Week 03

Path Planning and Obstacle Avoidance

Objectives
Global vs local planning, costmaps, recovery
Lab
Send goals and watch costmaps
Project
Avoid obstacles across a goal sequence
Week 04

Sensor Fusion and Decisions

Objectives
Multi-sensor estimates, supervisor states, stop conditions
Lab
Idle → navigate → avoid → recover → done
Project
Autonomous navigation robot

Month 06 06

Robotics Capstone Project

Architecture, integration, testing, documentation, and presentation.

Week 01

Robotics System Architecture

Objectives
Block diagram, interfaces, requirements list
Lab
Launch layout and interface inventory
Project
Freeze capstone scope
Week 02

Integration and Sim-to-Real

Objectives
Sim vs hardware, isolated tests, configuration records
Lab
One launch for mapping and navigation
Project
Connect perception, planning, and control
Week 03

Testing and Debugging

Objectives
Logs, recordings, metrics, defect reports
Lab
Reproduce a navigation failure
Project
Stabilize two demo conditions
Week 04

Documentation and Presentation

Objectives
System document, presentation, required behaviors, limitations
Lab
Demonstration recording with map overlay
Project
Final autonomous mobile robot delivery

Next cohort starts January 5, 2027

Enrollment deadline December 15, 2026. Program fee $1,499. Submit your registration to reserve a place in the six-month, project-centered program.

Apply / Register Now